Automated sorting cell
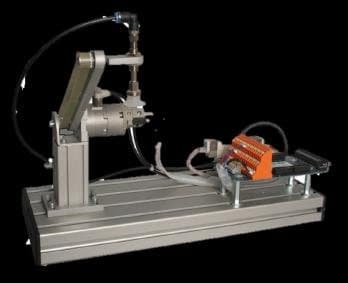
Software and control for a three-station PLC cell that queues, picks and sorts cylindrical parts by material and surface.
A three-station cell categorises cylindrical components by material and surface properties. A falling magazine queues and identifies each part, a swivel unit picks and places it with a vacuum suction gripper, and a linear sort unit pushes it to the right channel.
Identification uses an inductive sensor to tell metal from non-metal and an optical sensor to read reflectivity, with reed sensors confirming cylinder end positions.
What I did
- Delivered the software and control system for the cell.
- Developed and debugged the sequence logic, and resolved interaction issues between hardware and software.
- Implemented overflow and vacant-space detection, emergency-stop behaviour and status indication for reliable continuous operation.
From the bench
Linear sort unit that categorises each part
Optical sensor reading a part’s reflectivity
Reed sensor on a cylinder, with the terminal wiring